Teaching a Robot Hand to Walk
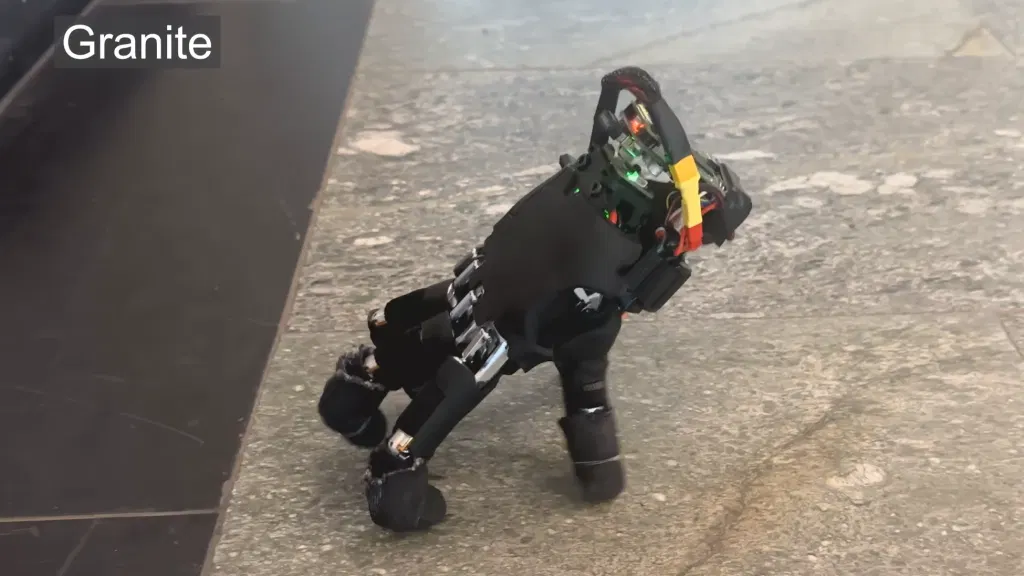
Researchers from ETH Zurich have developed a robotic hand capable of walking by using its fingers as legs. The device utilizes a neural network trained via reinforcement learning to control its twenty joints for various locomotion tasks. This innovation allows the hand to traverse different terrains, push objects, and potentially detach from larger robotic systems to reach distant targets.
- ▪The robotic hand was built using a commercially available hand, a battery, and a Raspberry Pi Zero 2 W.
- ▪A neural network controls the hand's twenty joints by iteratively outputting the next joint state based on previous movements and goals.
- ▪The hand successfully recovered from falls in 21 out of 25 tests, typically righting itself within twenty seconds.
- ▪The device demonstrated the ability to cross fourteen different surfaces and push light objects toward specific goals.
- ▪Researchers envision this technology allowing robotic hands to detach from arms and walk to extend the reach of larger robots.
Hackaday files mainly under tech. We currently carry 397 of its stories.
Story provenance
Source · retrieval · rights · ranking — open for full record
inspect →
Story provenance
Attribution is not the same as permission. This drawer separates discovery metadata, excerpts, WeSearch-generated summaries, reuse status, and whether the publisher receives the visit. Nothing here claims a legal grant the publisher has not made.
Record
| Original publisher | Hackaday |
| Canonical URL | https://hackaday.com/2026/09/19/teaching-a-robot-hand-to-walk/ |
| Publication time | Sat, 19 Sep 2026 17:00:37 +0000 |
| Retrieval time | 2026-09-19T17:03:46.628Z |
| Last seen | 2026-09-19T17:03:46.628Z |
| Headline source | Publisher (no WeSearch rewrite) |
| Excerpt source | publisher body |
| Excerpt method | First ~120 words (~800 chars) of extracted publisher body, fair-use limited. |
| Summary | WeSearch · cerebras-chat (WeSearch summarizer) |
| Summary source text | contentText |
| Citation coverage | Summary is a WeSearch-generated derivative; primary citation is the original publisher URL. |
| Cluster | FAbPveGu6foz · 1 stories |
| Cluster logic | Grouped by semantic title/content similarity across sources within a rolling window. Same-publisher template collisions are excluded from coverage comparison. |
| Ranking reason | Story pages are not engagement-ranked. Hub feeds use recency, with optional source-diversified chronological ordering (cap consecutive stories per source). No personalized ranking. |
| Publisher visit | Yes — open original |
| Substitutes article? | No — link-out required for full text |
Rights status (four layers)
WeSearch handling by dimension
| Indexing | May the item be indexed (stored, ranked, made findable)? | Allowed |
| Snippet | May a short excerpt of the publisher's text be shown? | Allowed |
| AI summary | May WeSearch generate its own short summary of the article? | Limited |
| Retrieval / RAG | May the content be exposed for third-party retrieval-augmented generation? | Not asserted |
| Model training | May the content be used to train AI models? | Not asserted |
| Commercial reuse | May the content be reused commercially? | Not permitted |
Basis: Derived from the published RSS/Atom feed. Contact: [email protected]. Reviewed: 2026-07-24.
Opening excerpt (first ~120 words) tap to expand
Teaching A Robot Hand To Walk No comments by: Aaron Beckendorf September 19, 2026 Title: Copy Short Link: Copy Although it wasn’t apparently designed with this in mind, it seems particularly fortuitous that this walking robotic hand was released in time for Halloween. Designed by researchers from ETH Zurich, the slightly unsettling disembodied hand can use its fingers as legs to traverse terrain, push small objects around, and operate a keyboard. The researchers started from commercially-available robot hand, equipped it with a battery and Raspberry Pi Zero 2 W, and developed neural net-based software to control it.
…
Excerpt limited to ~120 words for fair-use compliance. The full article is at Hackaday.
Discussion
0 commentsMore from Hackaday